Independent Robotics Research Platform

Evaluate robots before reality does.

ContactTrace Robotics explores simulation, robot-policy benchmarking, failure analysis and sim-to-real validation to make robotic systems more measurable, reproducible and reliable before deployment.

Simulation Isaac Sim · MuJoCo · ROS 2
Evaluation Benchmarks · CI · Metrics
Reality Robot validation · Sim-to-real
INTERACTIVE ROBOT TWIN
LIVE SIMULATION VIEW
CAPTURE → SIM → EVALUATE → REAL
Drag to rotate · Scroll to zoom

Research areas

Our work focuses on methods and infrastructure for understanding robot behavior, measuring performance, exposing failure modes and improving deployment readiness.

01

Robot Simulation

Physics-based robot and environment simulation for manipulation, navigation and embodied systems.

02

Policy Evaluation

Automated and repeatable testing of robotic policies across controlled scenarios and environments.

03

Failure Analysis

Identifying failure patterns and generating targeted scenarios that expose weaknesses in robotic policies.

04

Sim-to-Real

Comparing simulation and physical robot behavior to identify fidelity gaps and improve transfer.

05

Robot Manipulation

Experimental work involving grasping, Cartesian control, interaction and manipulation tasks.

06

Benchmarking

Objective metrics, batch experiments, automated regression testing and structured benchmark reporting.

From simulation to measurable evidence

Robotics systems should be evaluated systematically before hardware deployment rather than relying only on visually successful demonstrations.

01 · Simulate Build reproducible robot and environment scenarios.
→
02 · Evaluate Measure success, latency, errors and failure modes.
→
03 · Diagnose Identify weaknesses and generate targeted tests.
→
04 · Validate Compare against real-world robot behavior.

Featured research systems

Experimental systems exploring robotics simulation, automated evaluation and real-world deployment readiness.

PROJECT 01

Robot Evaluation Platform

ACTIVE

Automated infrastructure for running robot-policy experiments, detecting regressions, classifying failures and producing structured evaluation reports.

MuJoCo FastAPI CI Benchmarking
PROJECT 02

Real2Isaac

ACTIVE

Real-world-to-simulation pipeline that reconstructs captured environments and prepares them for physics and robot interaction inside NVIDIA Isaac Sim.

Real2Isaac prototype — from real-world capture to robot simulation
Isaac Sim COLMAP Gaussian Splatting USD
PROJECT 03

Failure-Aware Evaluation

RESEARCH

Investigation of automated robot-policy failure discovery and targeted scenario generation for evaluation, debugging and iterative improvement.

Failure Analysis Sim-to-Real Manipulation Robotics AI
Isaac Sim Simulation & Digital Twins
MuJoCo Physics & Evaluation
ROS 2 Robot Integration
Franka Manipulation Research

Research opportunities

ContactTrace Robotics welcomes students, researchers and independent contributors interested in practical robotics research with reproducible experiments and measurable outcomes.

TOPIC 01

Failure-Aware Robot Policy Evaluation

OPEN

Investigate methods for automatically identifying and classifying robot-policy failures including missed grasps, dropped objects, collisions, alignment errors and timeouts.

Python MuJoCo Isaac Sim Evaluation
TOPIC 02

Sim-to-Real Gap Measurement

OPEN

Compare simulated and physical robot behavior using trajectory, timing, force, contact and task-performance measurements to identify simulation fidelity gaps.

Franka ROS 2 Simulation Data Analysis
TOPIC 03

Automatic Scenario Generation

OPEN

Generate targeted simulation scenarios by varying object pose, friction, geometry, sensor conditions and environment parameters to expose policy weaknesses.

Python Benchmarking Simulation Robotics AI
TOPIC 04

Robot Policy Regression Testing

OPEN

Develop CI-style robotics testing where candidate controllers or policies are automatically compared against a baseline using repeatable simulation trials.

CI/CD MuJoCo Metrics Automation
TOPIC 05

Real-World-to-Simulation Automation

OPEN

Explore automated pipelines for converting phone captures or real-world observations into robot-ready simulation scenes with scale, collision geometry and environment structure.

Computer Vision 3D Reconstruction Isaac Sim Real2Sim
TOPIC 06

Human-Guided Robot Policy Correction

OPEN

Investigate whether human corrections to failed robot trajectories can be transformed into useful training or policy-improvement signals.

Teleoperation Manipulation Learning HRI

Interested in one of these topics?

Students and researchers can apply for independent research collaboration. Bachelor's and Master's thesis collaborations may also be possible subject to approval and academic supervision by the student's home university.

Apply for Research →

ContactTrace Sim

IN DEVELOPMENT

ContactTrace Sim is an emerging research platform concept for connecting real-world scene capture, robot import, simulation, automated policy evaluation and sim-to-real validation through a common workflow.

Capture → Build → Evaluate → Validate

The long-term goal is to make robotics simulation easier to create, easier to measure and easier to connect with physical deployment.

01 · Capture Capture a workspace using phone video, images or imported 3D assets.
→
02 · Build Generate a simulation scene and add robots through standard description formats.
→
03 · Evaluate Execute policies repeatedly and measure performance across controlled scenarios.
→
04 · Validate Compare simulation results against physical robot behavior.
REAL2SIM

Phone-to-Simulation

Extend real-world reconstruction toward automated, robot-ready scene generation from phone captures.

ROBOT IMPORT

Bring Your Own Robot

Designed to support robot-description formats such as URDF with links, joints, meshes, limits and collision models.

MULTI-BACKEND

Simulator Independent

Explore a common interface capable of targeting multiple simulation backends such as MuJoCo, Gazebo and Isaac Sim.

EVALUATION

Automated Benchmarks

Run batch experiments, compare candidate policies, classify failures and generate structured evaluation results.

ROS 2

Simulation-to-Robot Bridge

Use ROS 2 interfaces to connect simulated environments and physical robots through shared control workflows.

MOBILE

Browser & Phone Control

Explore mobile and browser interfaces for robot teleoperation, demonstrations, scene interaction and experiment control.

Interested in building robotics research together?

ContactTrace Robotics welcomes students, researchers, engineers and potential industry collaborators interested in simulation, robot-policy evaluation, benchmarking, real-world reconstruction and sim-to-real systems.

ContactTrace Robotics

ContactTrace Robotics is an independent robotics research initiative focused on making robot development more measurable and reproducible.

The platform explores simulation infrastructure, automated testing, failure-aware evaluation, real-world-to-simulation workflows and sim-to-real validation for embodied robotic systems.

01 Independent robotics research
02 Open technical experimentation
03 Student and researcher collaboration
04 Reproducible evaluation and benchmarking
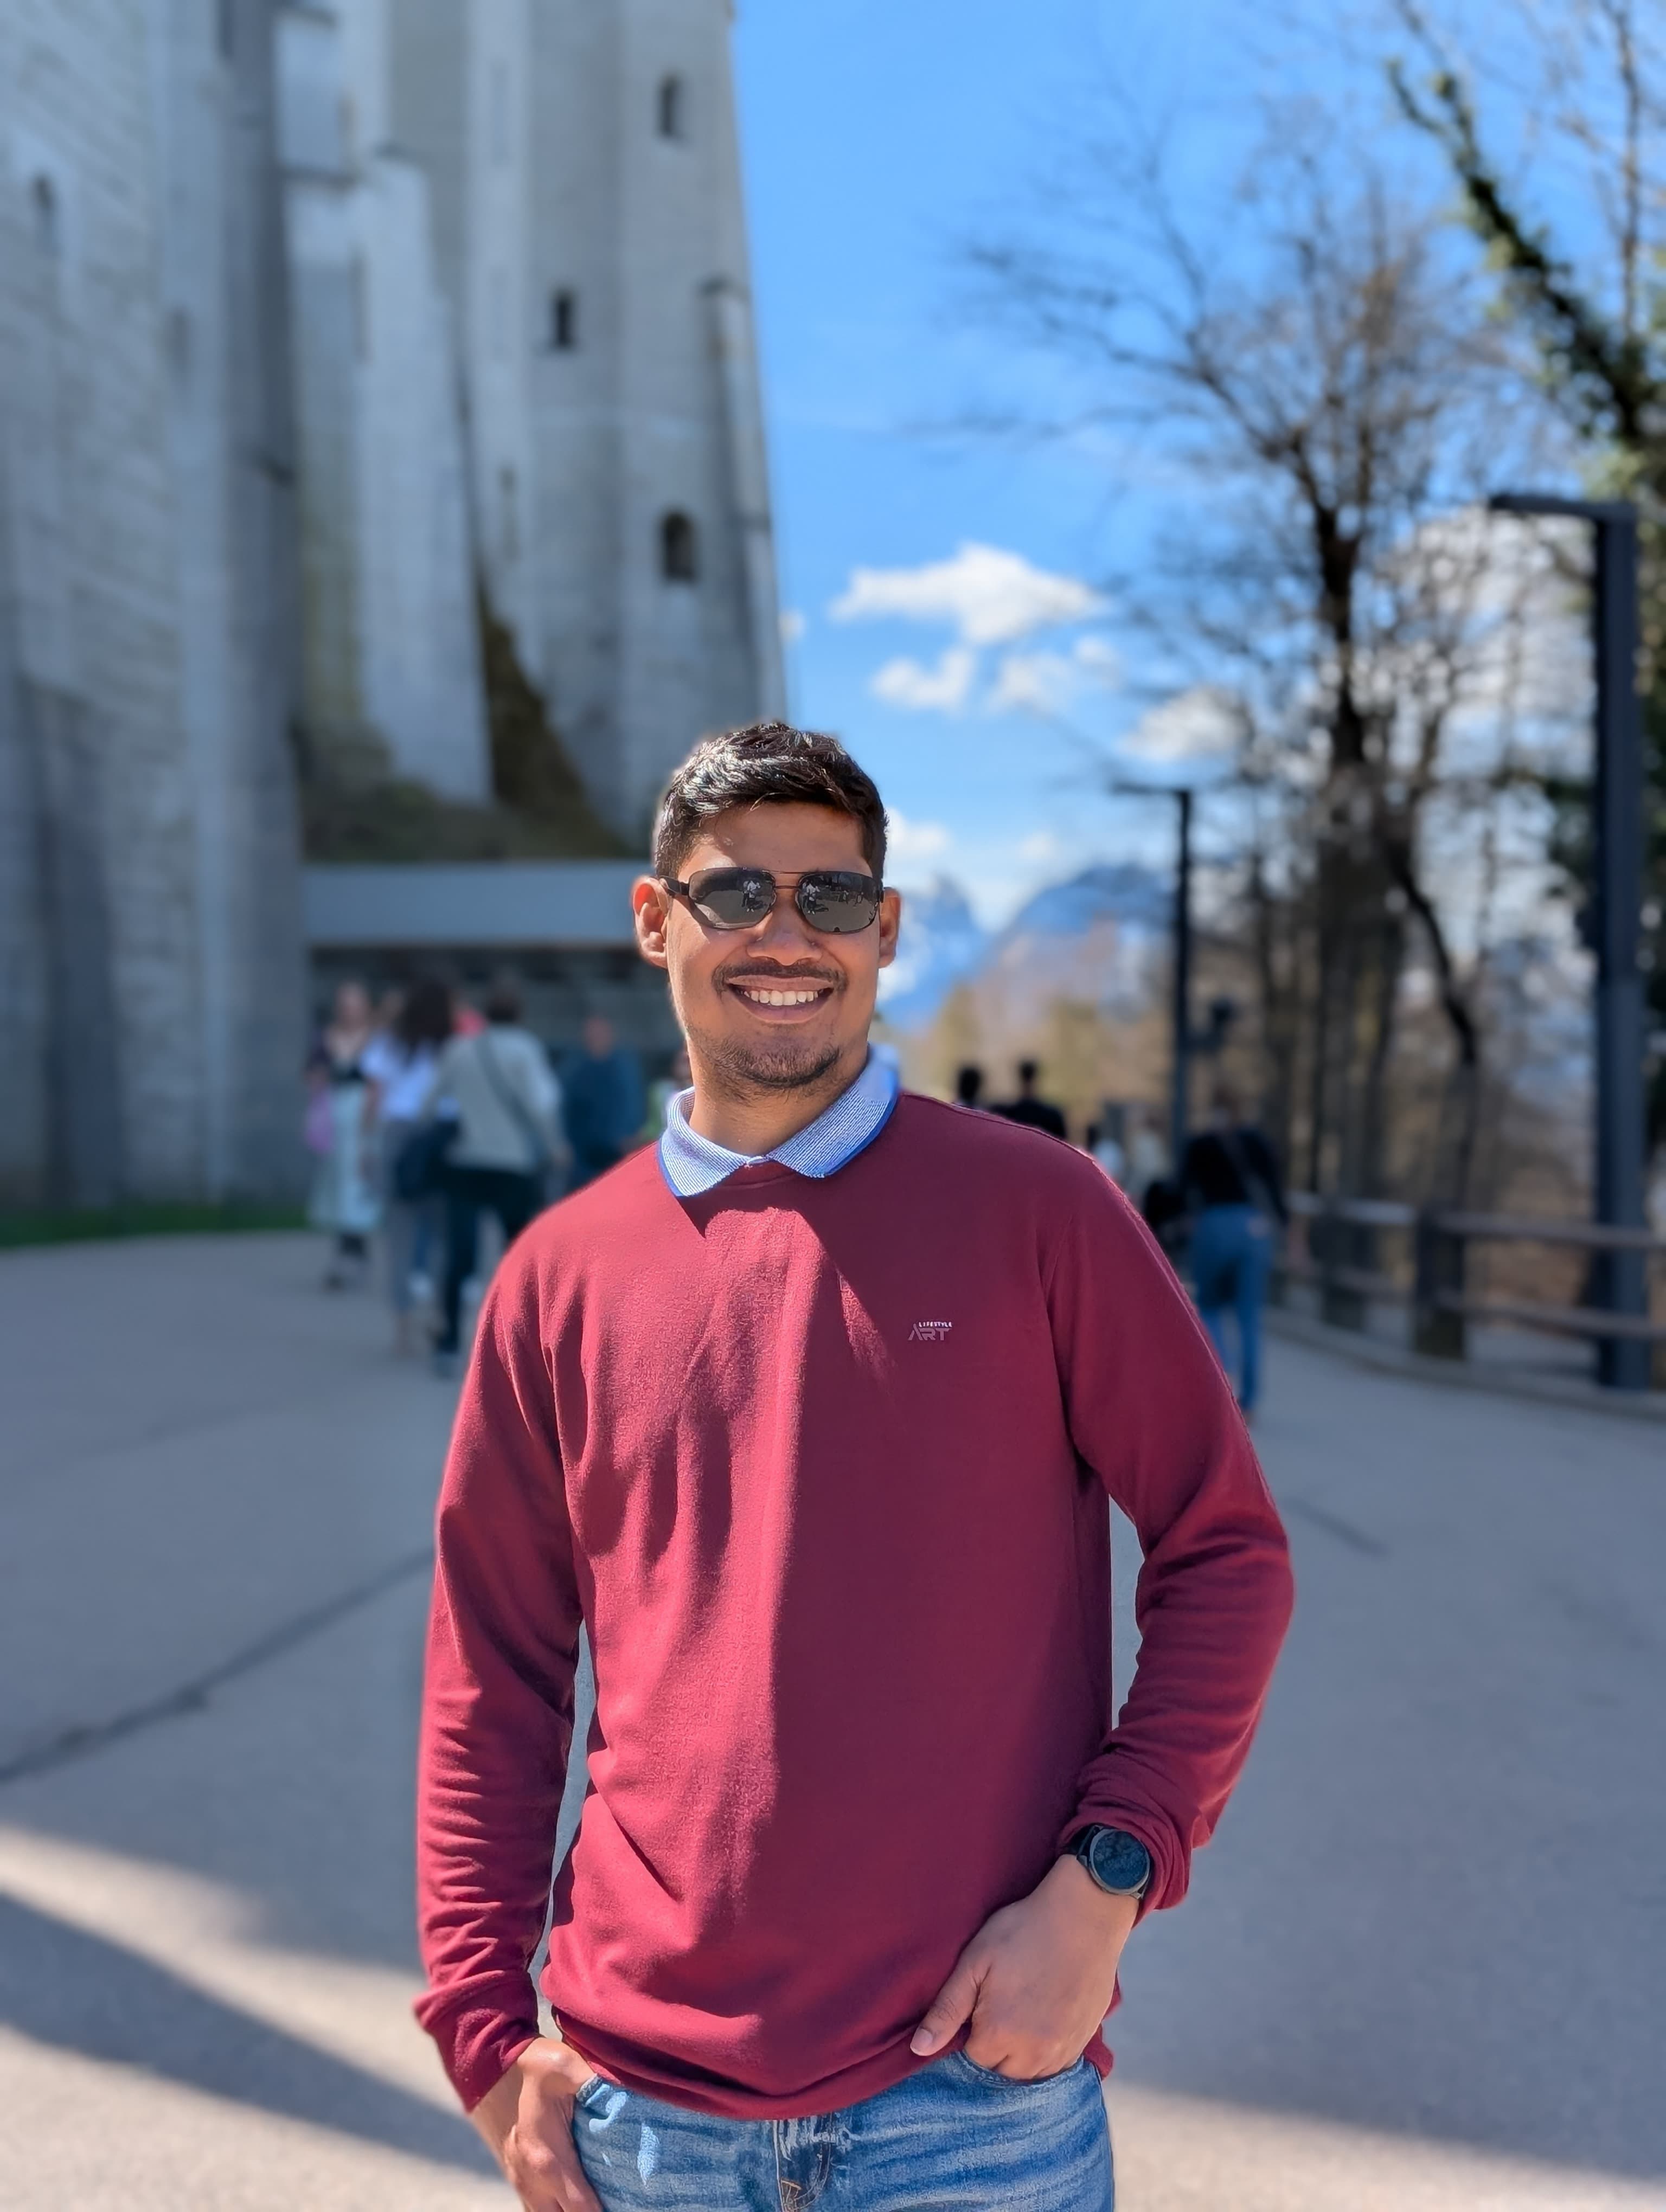
M A Hafiz

M A Hafiz

Founder & Robotics Research Engineer

Robotics engineer and researcher working on robot simulation, manipulation, automated evaluation, digital twins, robot control and sim-to-real systems.

ContactTrace Activity Public website activity
0 VISITORS